Ethan Lai
EE + CS @ Stanford — building at the intersection of Physical AI, world models, and low-latency systems.
NOW
▼ press startAbout
I'm an undergrad at Stanford University studying Electrical Engineering and Computer Science. I'm interested in Physical AI, world models, and low-latency, hardware-accelerated systems.
I like building things that bridge the gap between software and the physical world — whether that's quantized models for Physical AI or autonomous robots in space.
Most of my time goes into robots. Right now that means Deploy, a YC startup building production-grade robot deployments, and the Tambe Lab, where I'm getting vision-language-action models small enough to run on the computer that sits on the robot. It's PyTorch in the morning and C in the afternoon. Last summer I was a forward-deployed engineer at Wedge, another YC startup, which mostly meant getting ML pipelines to run on old hospital servers without breaking anything HIPAA cares about. The thread through all of it is latency: making models small and fast enough for the hardware that is actually there.
If any of that sounds interesting, email me at ethanlai@stanford.edu.
Experience
Robot Learning Intern @ DeployYC F26
Sep 2026 – PresentEarly-stage startup building production-grade robot deployments for enterprises.
Physical AI Researcher @ Tambe Group, Stanford
Feb 2026 – PresentCustom firmware and memory architectures for VLA models
Forward Deployed Engineer @ WedgeYC S25
Aug – Nov 2025Early-stage startup building ML infrastructure for healthcare systems.
Projects
4 wins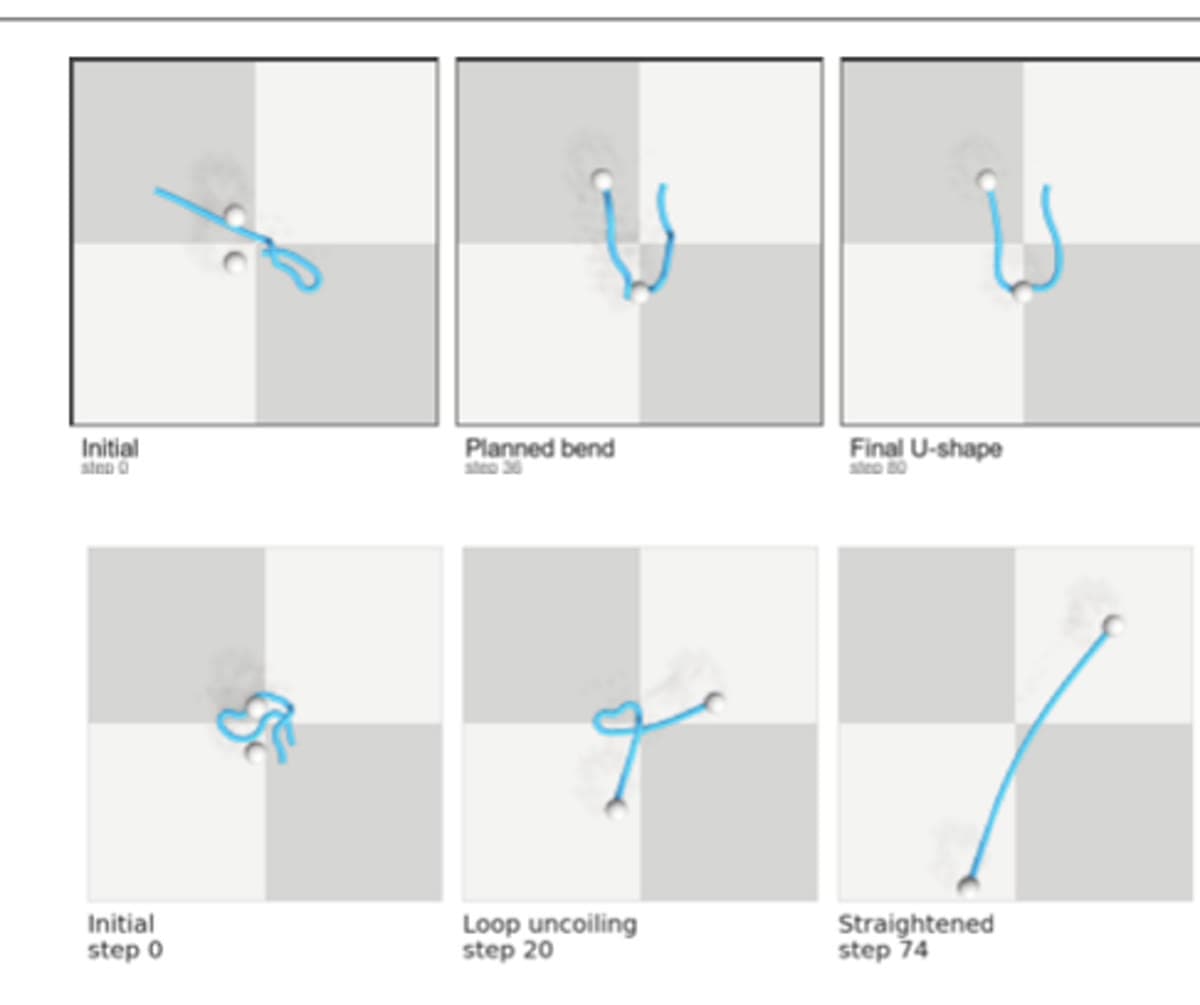
lv 01
Latent World Modeling
CS 231n Final Project
A compact JEPA-based latent world model for deformable-object manipulation from RGB observations.
- Deep Learning
- World Models
- Robotics
lv 02
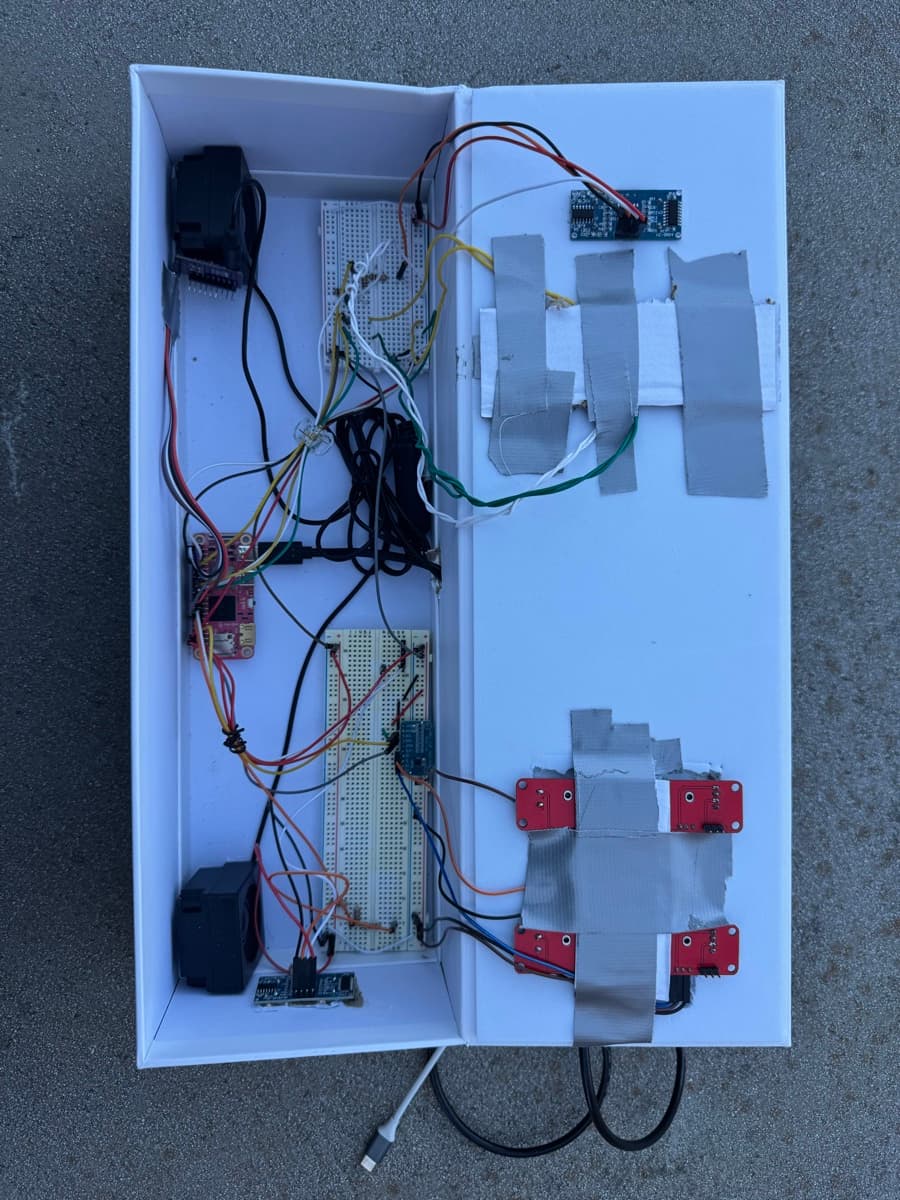
Bare-Metal Embedded Theremin
CS 107e Final Project
A bare-metal musical theremin on Mango Pi with real-time sensor input and I2S audio output.
- Embedded
- C
- Audio
- 2nd Place + $20,000
lv 03
CANOPY
Army xTech 3rd National Security Hackathon
An autonomous drone-satellite space communication system for national security.
- Space
- Drones
- Comms
- 2nd Place
lv 04
RECON
YC RoboHacks 2026
An autonomous bomb defusal robot for rescue scenarios.
- Robotics
- VLM
- ROS2
- NVIDIA Edge AI Winner
lv 05
Detour
TreeHacks 2026
An autonomous collision avoidance system for space debris.
- AI
- Space
- Python
- AI Design Track Winner
lv 06
Anatomist
CalHacks 12.0
An AR-based 3D anatomy app for real-time rendering.
- AR
- 3D
- Education
Stack
Technical
- Isaac Lab
- MuJoCo
- ROS2
- Raspberry Pi
- RISC-V
- CUDA
- LangChain
- Fusion 360
- Onshape
- MATLAB
Programming
- C
- Python
- C++
- PyTorch
- Verilog
- RTL
- NumPy
- SQL
- React
- Next.js